 |
ScummVM API documentation
|


|
|
ScummVM API documentation
|
|
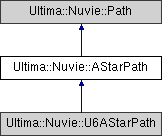
Public Member Functions | |
| bool | path_search (const MapCoord &start, const MapCoord &goal) override |
| uint32 | path_cost_est (const MapCoord &s, const MapCoord &g) override |
| uint32 | get_max_score (uint32 cost) override |
| uint32 | path_cost_est (const astar_node &n1, const astar_node &n2) |
| sint32 | step_cost (const MapCoord &c1, const MapCoord &c2) override |
 Public Member Functions inherited from Ultima::Nuvie::Path | |
| void | set_pathfinder (PathFinder *pathfinder) |
| virtual bool | path_search (const MapCoord &start, const MapCoord &goal)=0 |
| void | delete_path () |
| virtual bool | have_path () |
| virtual sint32 | step_cost (const MapCoord &c1, const MapCoord &c2)=0 |
| virtual uint32 | path_cost_est (const MapCoord &s, const MapCoord &g) |
| virtual uint32 | get_max_score (uint32 cost) |
| virtual const MapCoord & | get_first_step () |
| virtual const MapCoord & | get_last_step () |
| virtual const MapCoord & | get_step (uint32 step_index) |
| virtual void | get_path (MapCoord **path_start, uint32 &path_size) |
| uint32 | get_num_steps () |
| virtual bool | remove_first_step () |
Protected Member Functions | |
| void | create_path () |
| bool | search_node_neighbors (astar_node *nnode, const MapCoord &goal, const uint32 max_score) |
| bool | compare_neighbors (astar_node *nnode, astar_node *neighbor, sint32 nnode_to_neighbor, astar_node *in_open, astar_node *in_closed) |
| bool | score_to_neighbor (sint8 dir, astar_node *nnode, astar_node *neighbor, sint32 &nnode_to_neighbor) |
| astar_node * | find_open_node (astar_node *ncmp) |
| void | push_open_node (astar_node *node) |
| astar_node * | pop_open_node () |
| astar_node * | find_closed_node (astar_node *ncmp) |
| void | remove_closed_node (astar_node *ncmp) |
| void | delete_nodes () |
| Protected Member Functions inherited from Ultima::Nuvie::Path | |
| void | add_step (const MapCoord &loc) |
| bool | check_dir (const MapCoord &loc, MapCoord &rel) |
| bool | check_loc (const MapCoord &loc) |
| void | set_path_size (int alloc_size) |
Protected Attributes | |
| Common::List< astar_node * > | open_nodes |
| Common::List< astar_node * > | closed_nodes |
| astar_node * | final_node |
| Protected Attributes inherited from Ultima::Nuvie::Path | |
| MapCoord * | path |
| uint32 | step_count |
| uint32 | path_size |
| PathFinder * | pf |
|
overridevirtual |
Implements Ultima::Nuvie::Path.
|
inlineoverridevirtual |
Reimplemented from Ultima::Nuvie::Path.
|
inlineoverridevirtual |
Reimplemented from Ultima::Nuvie::Path.
|
overridevirtual |
Implements Ultima::Nuvie::Path.
 1.9.4